THE SIGNAL IN ONE SENTENCE
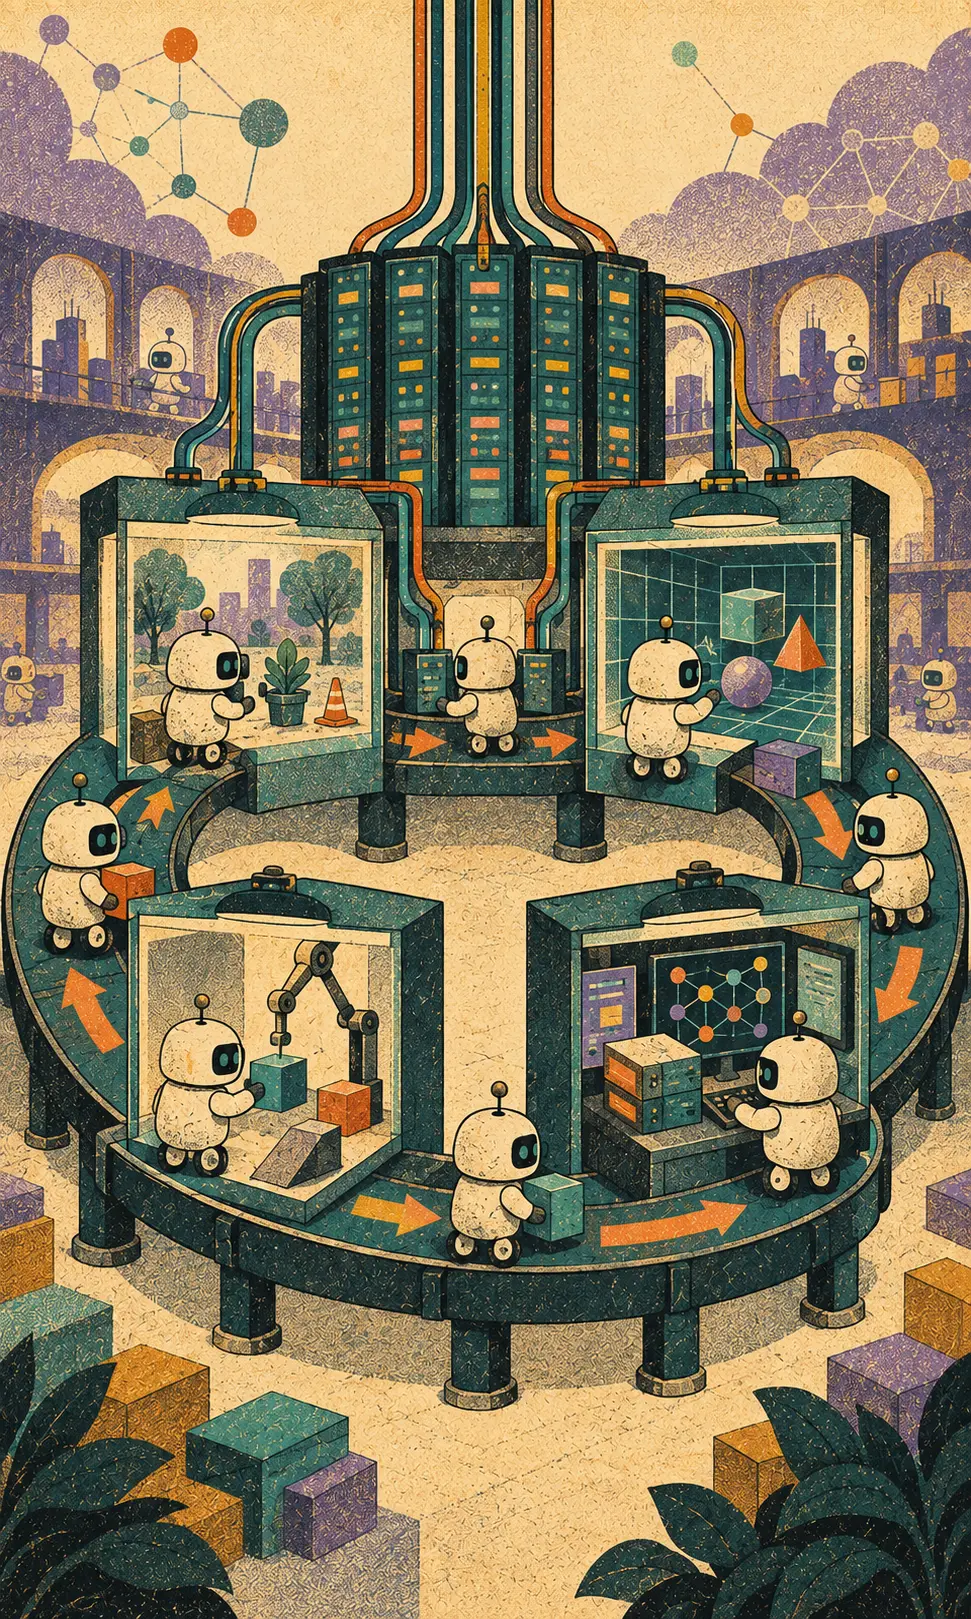
Instead of treating robot intelligence as one training job, a new reference architecture keeps simulation, training, and evaluation running as one repeating production loop.
01
WHAT ACTUALLY CHANGED
AWS published a reference architecture for building a physical AI model factory with Nvidia Cosmos 3 and SageMaker HyperPod. The pipeline continuously generates synthetic data, trains perception and action models, evaluates them in closed-loop simulation, and feeds the results into the next round.
Cosmos 3 treats video, images, actions, and sound as one token stream. The same transformer family can operate as a forward-dynamics world model that predicts what happens next, an inverse-dynamics labeler that infers actions from observations, or a deployable action policy.
The architecture keeps one persistent pool of GPU nodes and shares it among stages instead of separately acquiring and releasing capacity for data generation, training, and evaluation. AWS provides an end-to-end robot-policy example using the public DROID dataset.
AWS argues that the useful economic measurement is GPU goodput, meaning productive pipeline progress per reserved GPU-hour. A spectacularly fast training stage does not help much when the expensive machines sit idle while another stage waits for capacity or data.
02
WHY THIS MATTERS
A robot does not become reliable because somebody runs one enormous training command and goes to lunch. Physical systems need a continuing loop between messy reality, controlled simulation, model training, and tests that expose the next failure.
That makes the operational system a competitive asset. The model checkpoint can change, but a factory that continually turns fresh observations into tested behavior becomes the durable mechanism for improvement.
The unified model design is also interesting because it reduces the number of disconnected translators between seeing, predicting, labeling, and acting. Fewer seams do not guarantee safer behavior, but they can make the learning loop more coherent and easier to operate.
03
WHERE IT COULD HELP
- Train warehouse and industrial robots
- Generate synthetic driving and manipulation scenarios
- Infer action labels from recorded demonstrations
- Test policies in simulation before deploying them to physical machines
KEEP A HAND ON THE WHEEL
This is a vendor-authored reference design, not evidence that a deployed robot became safer or more capable. Teams still need real-world validation, failure testing, emergency controls, data-quality checks, and a careful accounting of the cost and energy consumed by the continuous loop.
04
TERMS WORTH KEEPING
OPEN GLOSSARY CARD
Inference
The moment a trained model uses what it learned to produce an answer.
OPEN GLOSSARY CARD
Foundation model
A broadly trained model that can be adapted or prompted for many different tasks.
OPEN GLOSSARY CARD
Evaluation gate
A required test or review that a system must pass before it advances to the next stage.
SOURCES AND VERIFICATION STATUS
This article was written from the materials below. Product claims and dates were checked against those sources on September 4, 2026.
PUBLICATION RECEIPT: Revision 1. Approved by Zak and published September 4, 2026.
THE PUBLICATION ENGINE
WANT A SIGNAL OF YOUR OWN?
We build source-grounded publications, private briefings, and editorial systems for organizations with something useful to say.
WORK WITH US